7.5.19 LIN User Guide
The S100 MCU chip has 3 LIN channels in total (LIN0~LIN2), among which LIN1 is routed out through an on-board connector for user development and learning, and is configured as a Master node.
| Configuration Item | LIN1 |
|---|---|
| Node type | Master |
| Baud rate | 9600 bps |
| Stop bits | 1 bit |
| Auto baud rate | Disabled |
| Wakeup detection | Disabled |
| Break field length | 13 bit |
| Response timeout | 14 bit time |
| Header timeout | 44 bit time |
Hardware Support
- Maximum number of LIN channels available on the MCU: 3 (LIN0~LIN2)
- LIN channels routed out on the board: 1 (LIN1)
- Supported LIN protocol versions: 1.3, 2.0, 2.1, 2.2
- Supports Master/Slave node modes
- Data buffering: single 8-byte buffer or FIFO mode
- Supports 16 identifiers (Identifier Filters)
- Supports Classic Checksum and Enhanced Checksum
- Baud rate: up to 20 Kbit/s (LIN protocol standard), with support for a fractional baud rate generator
- Power modes: Initialization, Normal, Sleep
- Timeout management: Header timeout, Response timeout, Frame timeout
- Advanced error detection: supports multiple kinds of LIN error detection
- Wakeup support: wakeup on Dominant bit detection
- Interrupt support: maskable interrupts
- External transceiver: an external LIN transceiver chip is required to connect to the LIN bus
The S600 MCU chip has 8 LIN channels in total (LIN0~LIN7), among which LIN2 and LIN3 are routed out through on-board connectors for user development and learning, and both are configured as Master nodes.
| Configuration Item | LIN2 | LIN3 |
|---|---|---|
| Node type | Master | Master |
| Baud rate | 9600 bps | 9600 bps |
| Stop bits | 1 bit | 1 bit |
| Auto baud rate | Disabled | Disabled |
| Wakeup detection | Disabled | Disabled |
| Break field length | 13 bit | 13 bit |
| Response timeout | 14 bit time | 14 bit time |
| Header timeout | 44 bit time | 44 bit time |
Hardware Support
- Maximum number of LIN channels available on the MCU: 8 (LIN0~LIN7)
- LIN channels routed out on the board: 2 (LIN2, LIN3)
- Supported LIN protocol versions: 1.3, 2.0, 2.1, 2.2
- Supports Master/Slave node modes
- Data buffering: single 8-byte buffer or FIFO mode
- Supports 16 identifiers (Identifier Filters)
- Supports Classic Checksum and Enhanced Checksum
- Baud rate: up to 20 Kbit/s (LIN protocol standard), with support for a fractional baud rate generator
- Power modes: Initialization, Normal, Sleep
- Timeout management: Header timeout, Response timeout, Frame timeout
- Advanced error detection: supports multiple kinds of LIN error detection
- Wakeup support: wakeup on Dominant bit detection
- Interrupt support: maskable interrupts
- External transceiver: an external LIN transceiver chip is required to connect to the LIN bus
Software Architecture
- LIN APP: The LIN application layer code.
- LIN Interface: The LIN interface layer code, which provides standardized LIN operation interfaces.
- LIN LLD: The LIN low-level driver code, which directly operates the LINFLEXD registers and implements core functions such as frame transmission/reception and interrupt handling.
- LIN PBcfg: The LIN PB configuration file, used for peripheral configuration parameters.
- Hardware: The LINFLEXD hardware.
Code Paths
McalCdd/Common/Register/inc/Lin_Register.h: Register-related contentMcalCdd/Lin/src/Lin.c: API layer codeMcalCdd/Lin/src/Lin_Lld.c: LLD layer codeMcalCdd/Lin/src/Linflexd_Lin_Ip.c: IP layer codeMcalCdd/Lin/src/Lin_Irq.c: Interrupt handling codeMcalCdd/Lin/src/LinIf.c: LIN Interface callback stubsMcalCdd/Lin/inc/Lin.h: Public API header fileMcalCdd/Lin/inc/Lin_GeneralTypes.h: Standard type definitionsMcalCdd/Lin/inc/Lin_Types.h: Configuration structure typesMcalCdd/Lin/inc/Lin_Lld.h: Low-level driver interface declarationsMcalCdd/Lin/inc/Linflexd_Lin_Ip.h: LINFLEXD IP layer interfacesMcalCdd/Lin/inc/Lin_Irq.h: Interrupt handling declarationsConfig/McalCdd/gen_xxx/Lin/src/Lin_PBcfg.c: PostBuild configuration file
Application Sample
Usage Example
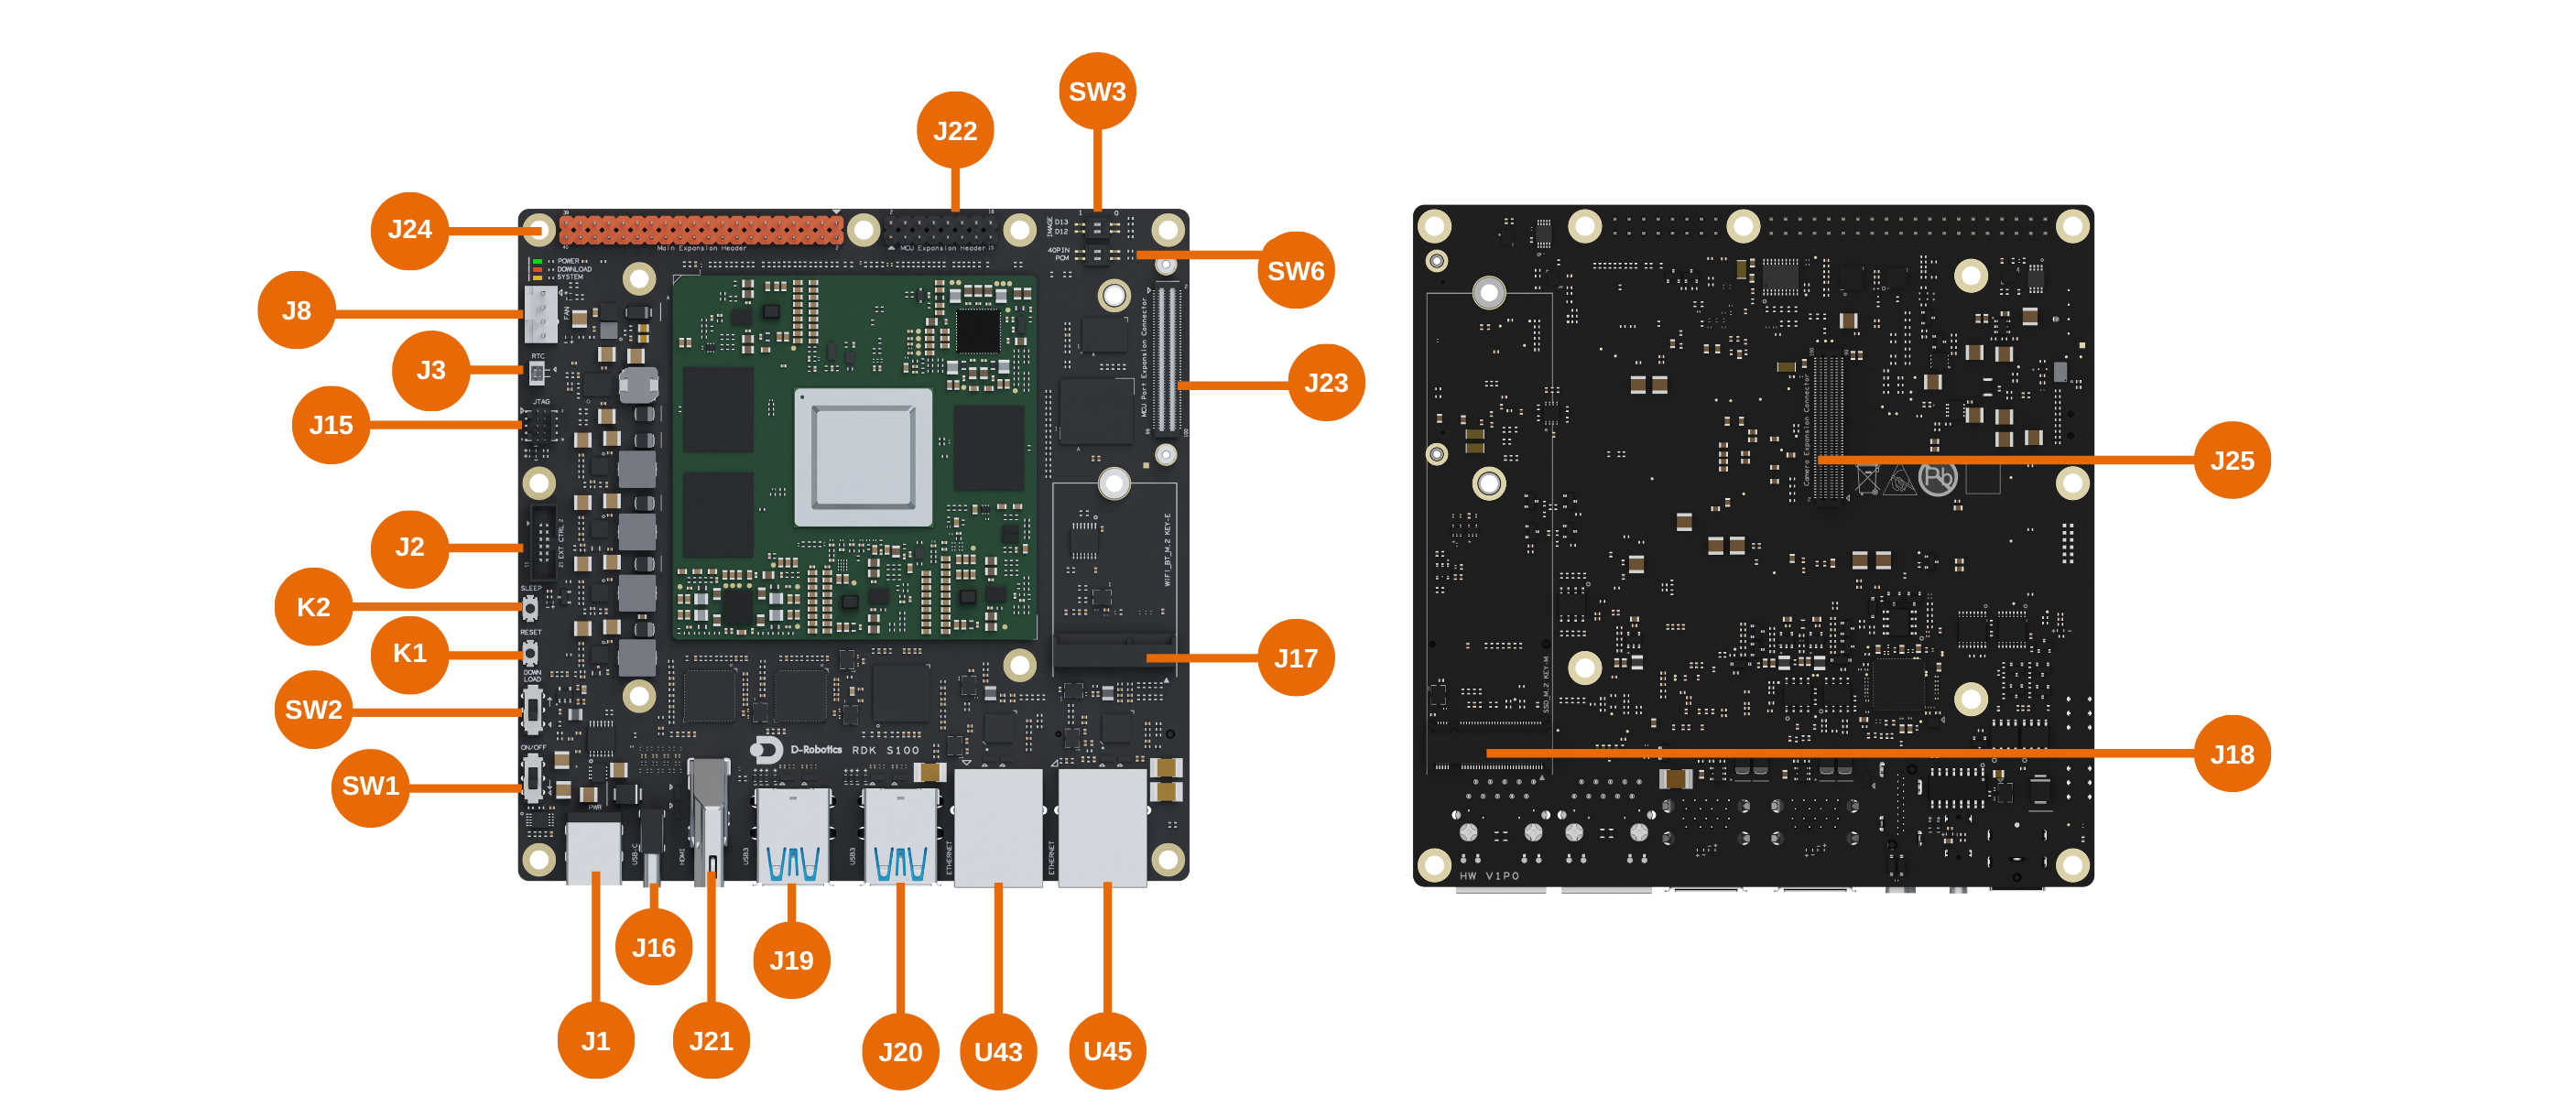
The S100 development board routes LIN1 out for user development and learning; the pins are located on the MCU Port Expansion Header(J22) on the Main Board:
LIN1 multiplexes the UART5 pins. Running the LinTest command will automatically mux the corresponding pins to the LIN function, and the UART function can no longer be used.
To restore it, use the command uarttest 0 5 921600 0 1 8, or call Port_SetFunctionPins(PORT_FUNC_UART5) to reconfigure the serial pins.
| Signal | Pin |
|---|---|
| LIN1_TX | J22 PIN13 |
| LIN1_RX | J22 PIN15 |
- Syntax
case: Test case ID (required)channel: LIN channel number (0=LIN1)Pid: Frame ID (0-0x3F)ChecksumType: Checksum type (0=ENHANCED, 1=CLASSIC)ResponseType: Response type (0=TX, 1=RX)DataLen: Data length (1-8)loop_times: Number of loops
LinTest <case> <channel> <Pid> <ChecksumType> <ResponseType> <DataLen> <loop_times>
LinTest 1prints driver version information
D-Robotics:/$ LinTest 1
[get_Lin_status 113] [INFO]: Lin status: LIN_CH_SLEEP
[LinTest 290] [INFO]: ####################### test_case_num: 1 #######################
vendorID: 0xC4
moduleID: 0x52
sw_major_version: 1
sw_minor_version: 0
sw_patch_version: 0
[LinTest 305] [INFO]: Test case pass.
[LinTest 310] [INFO]: #####################################################################
LinTest 2 0 16 0 0 8 1sends data on LIN1
D-Robotics:/$ LinTest 2 0 16 0 0 8 1
[get_Lin_status 113] [INFO]: Lin status: LIN_CH_SLEEP
[LinTest 290] [INFO]: ####################### test_case_num: 2 #######################
############################# Loop Times: 1 #############################
[Lin_Transfer_Test 214] [INFO]: Transfer success.
[get_Lin_status 86] [INFO]: Lin status: LIN_TX_OK
[LinTest 305] [INFO]: Test case pass.
[LinTest 310] [INFO]: #####################################################################
Usage Example
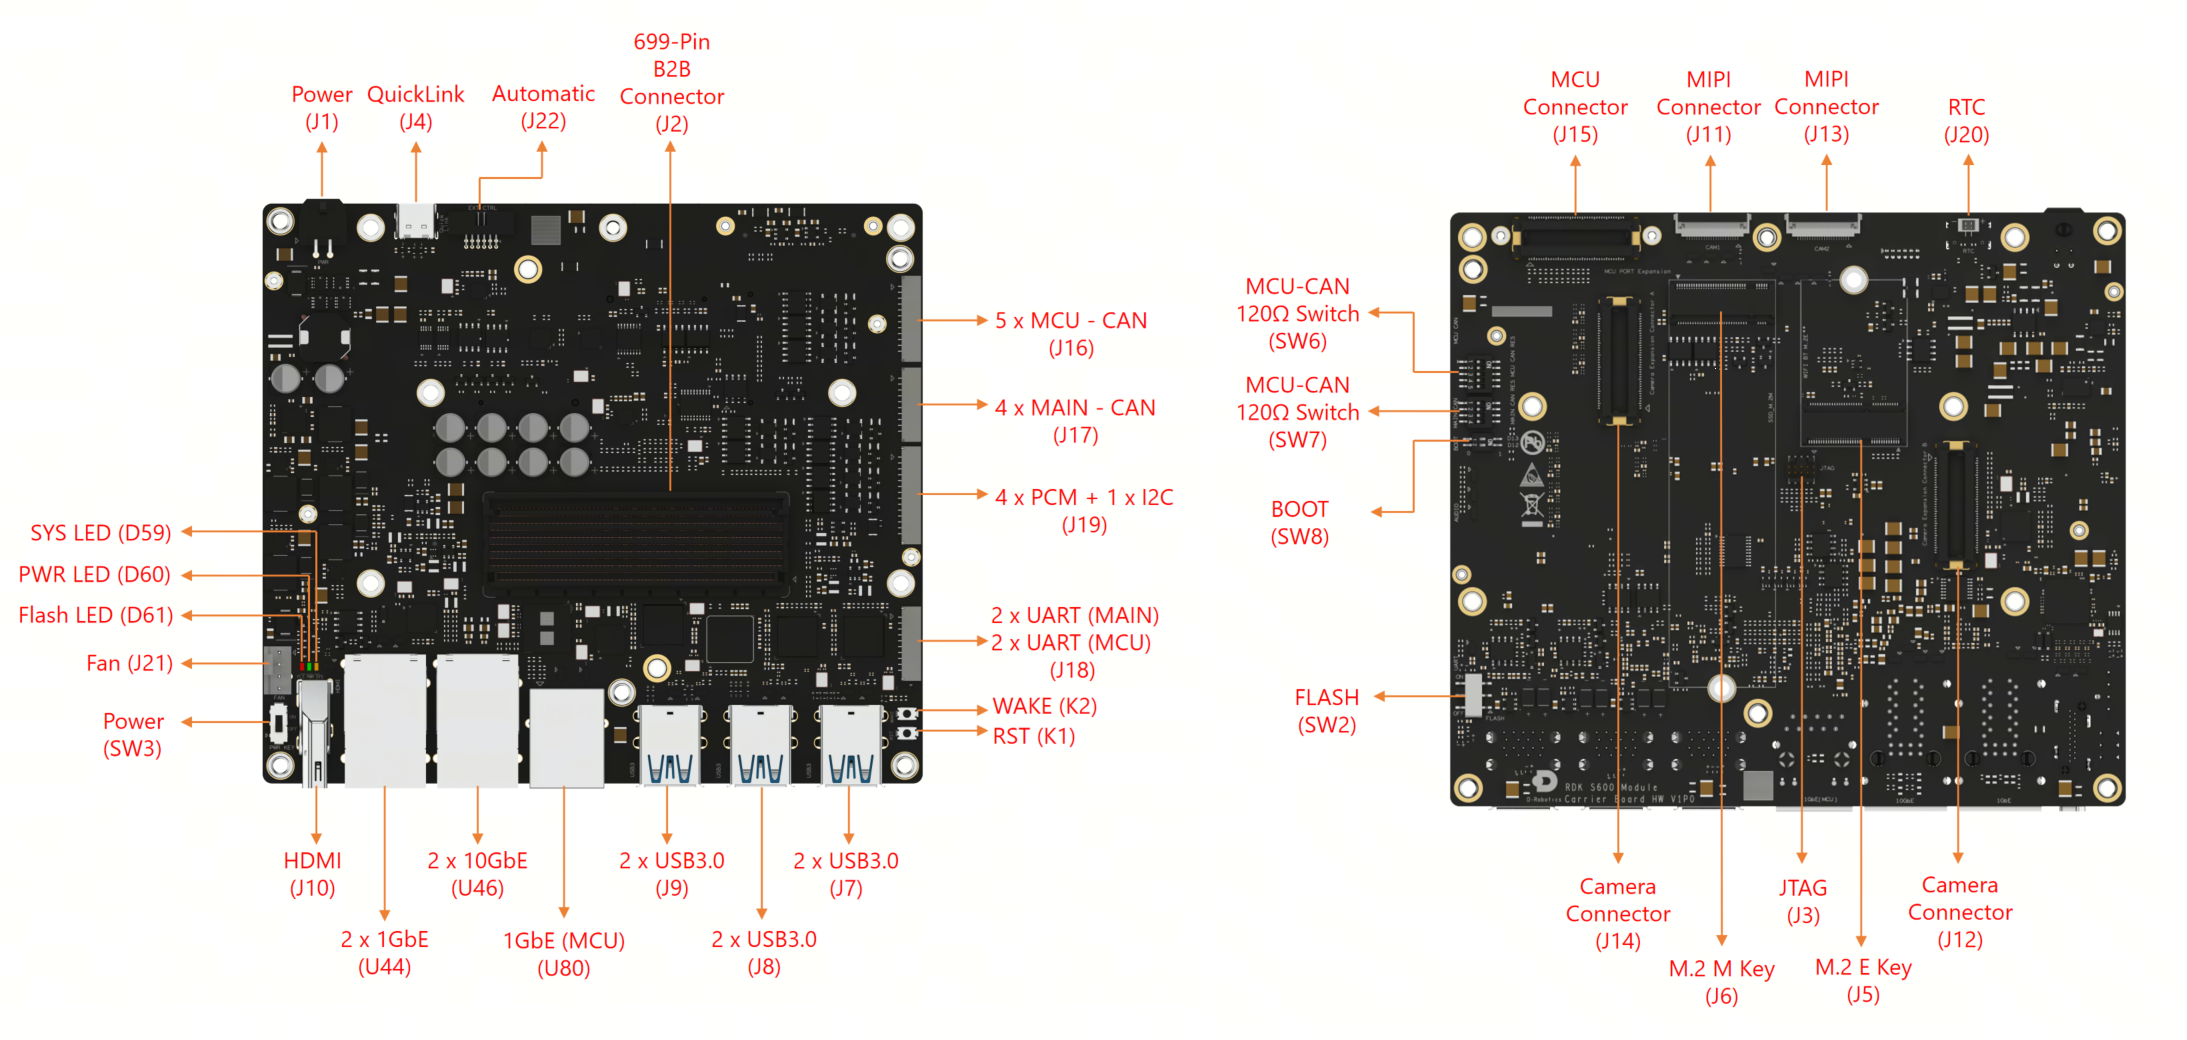
The S600 development board routes LIN2 and LIN3 out for user development and learning; the pins are located on the connector J18 on the Main Board:
LIN2 multiplexes the UART10 pins and LIN3 multiplexes the UART11 pins. Running the LinTest command will automatically mux the corresponding pins to the LIN function, and the UART function can no longer be used.
To restore it, use the command uarttest 0 10/11 921600 0 1 8, or call Port_SetFunctionPins(PORT_FUNC_UART10/11) to reconfigure the serial pins.
| Signal | Pin |
|---|---|
| LIN2_TX | J18 PIN2 |
| LIN2_RX | J18 PIN3 |
| LIN3_TX | J18 PIN4 |
| LIN3_RX | J18 PIN5 |
- Syntax
case: Test case ID (required)channel: LIN channel number (0=LIN2, 1=LIN3)Pid: Frame ID (0-0x3F)ChecksumType: Checksum type (0=ENHANCED, 1=CLASSIC)ResponseType: Response type (0=TX, 1=RX)DataLen: Data length (1-8)loop_times: Number of loops
LinTest <case> <channel> <Pid> <ChecksumType> <ResponseType> <DataLen> <loop_times>
LinTest 1prints driver version information
D-Robotics:/$ LinTest 1
[get_Lin_status 113] [INFO]: Lin status: LIN_CH_SLEEP
[LinTest 290] [INFO]: ####################### test_case_num: 1 #######################
vendorID: 0xC4
moduleID: 0x52
sw_major_version: 1
sw_minor_version: 0
sw_patch_version: 0
[LinTest 305] [INFO]: Test case pass.
[LinTest 310] [INFO]: #####################################################################
LinTest 2 0 16 0 0 8 1sends data on LIN2
D-Robotics:/$ LinTest 2 0 16 0 0 8 1
[get_Lin_status 113] [INFO]: Lin status: LIN_CH_SLEEP
[LinTest 290] [INFO]: ####################### test_case_num: 2 #######################
############################# Loop Times: 1 #############################
[Lin_Transfer_Test 214] [INFO]: Transfer success.
[get_Lin_status 86] [INFO]: Lin status: LIN_TX_OK
[LinTest 305] [INFO]: Test case pass.
[LinTest 310] [INFO]: #####################################################################
Application Programming Interface
void Lin_Init(const Lin_ConfigType *Config)
Description: LIN driver initialization. Pass NULL to use the default configuration in Lin_PBcfg.c.

Parameters(in)
    Config: Pointer to LIN configuration (NULL = use default PostBuild configuration)
Parameters(inout)
    None
Parameters(out)
    None
Return value: None
Std_ReturnType Lin_SendFrame(uint8 Channel, const Lin_PduType *PduInfoPtr)
Description: Master starts a frame transfer on the given channel (TX: send data / RX: send header and receive the slave response).

Parameters(in)
    Channel: LIN channel
    PduInfoPtr: Pointer to the frame descriptor (Pid / Cs / Drc / Dl / SduPtr)
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: transfer started successfully
    E_NOT_OK: failed
Lin_StatusType Lin_GetStatus(uint8 Channel, uint8 **Lin_SduPtr)
Description: Get the transfer status of a channel; on receive completion the received data buffer is returned through Lin_SduPtr.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    Lin_SduPtr: Pointer to the received data buffer (valid when RX completes)
Return value: Lin_StatusType
    Current channel status (LIN_TX_OK / LIN_RX_OK / LIN_TX_BUSY / LIN_RX_BUSY, etc.)
Std_ReturnType Lin_GoToSleep(uint8 Channel)
Description: Send a go-to-sleep command on the channel and enter sleep.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: success
    E_NOT_OK: failed
Std_ReturnType Lin_GoToSleepInternal(uint8 Channel)
Description: Set the channel to sleep directly, without sending a command on the bus.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: success
    E_NOT_OK: failed
Std_ReturnType Lin_Wakeup(uint8 Channel)
Description: Send a wakeup pulse on the bus.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: success
    E_NOT_OK: failed
Std_ReturnType Lin_WakeupInternal(uint8 Channel)
Description: Set the channel to operational, without sending a wakeup pulse.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: success
    E_NOT_OK: failed
Std_ReturnType Lin_CheckWakeup(uint8 Channel)
Description: Check the wakeup event of the given channel.

Parameters(in)
    Channel: LIN channel
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: success
    E_NOT_OK: failed
void Lin_GetVersionInfo(Std_VersionInfoType *versioninfo)
Description: Get LIN driver version information.

Parameters(in)
    None
Parameters(inout)
    None
Parameters(out)
    versioninfo: Version information struct (vendorID / moduleID / sw version)
Return value: None
Std_ReturnType Port_SetFunctionPins(PinFunc_e PinFunc)
Description: Configure the pin mux for the given function. Must be called before using LIN.

Parameters(in)
    PinFunc: Pin function (S100: PORT_FUNC_LIN1 / S600: PORT_FUNC_LIN2, PORT_FUNC_LIN3)
Parameters(inout)
    None
Parameters(out)
    None
Return value: Std_ReturnType
    E_OK: set success
    E_NOT_OK: set failed